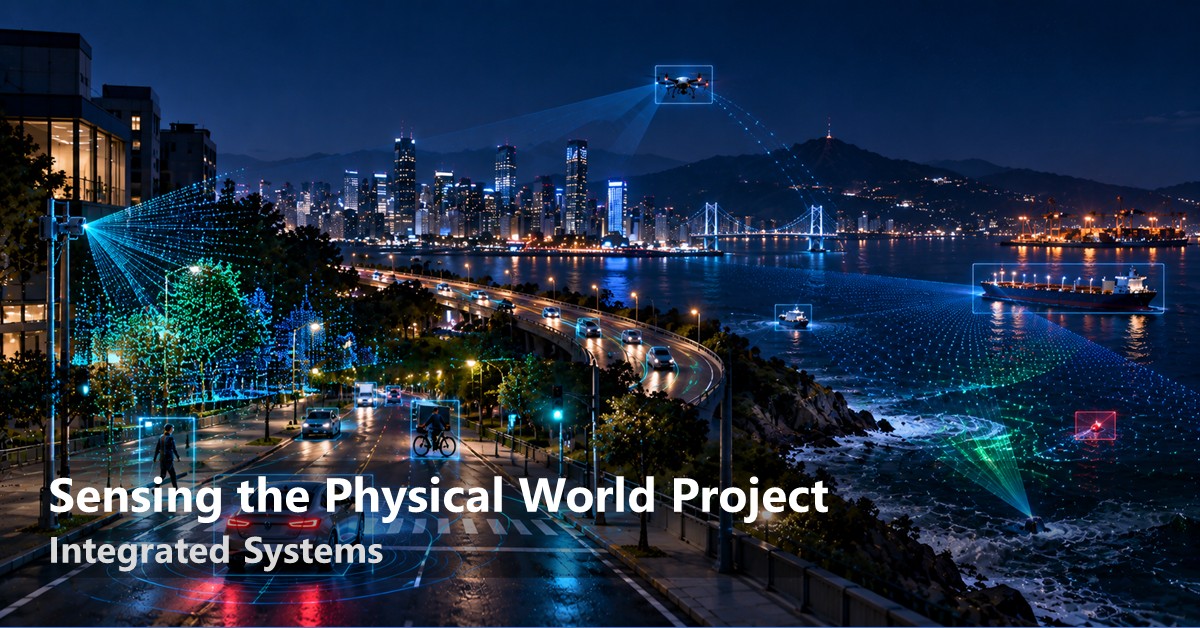
Cameras alone cannot provide that picture. They see only what is in front of them, under favorable lighting and without obstruction. Yet many of the situations that matter most occur beyond those limits. The collision a vehicle needs to avoid may involve another vehicle hidden around a corner. The traffic conflict a city needs to understand may unfold across an area no single camera can cover. The marine debris an environmental agency wants to measure may be scattered across miles of open water that nobody is continuously watching. New sensing technologies can extend perception beyond these boundaries. Roadside LiDAR, automotive radar, RF sensing, and crowdsourced sensors can detect and track activity across occlusions, darkness, distance, and large physical spaces. Together, they create the possibility of understanding environments that camera-only systems cannot reliably observe.
But infrastructure-scale sensing has a different economic constraint from a laboratory demonstration. Transportation authorities, infrastructure operators, and environmental agencies deploy systems that may need to operate continuously for years. What matters is not simply peak accuracy, but how much physical space can be covered, at what cost, and how much data the system must continuously collect, transmit, and process. A sensing system only becomes useful infrastructure if its economics scale with its coverage. We are building toward a persistent, infrastructure-scale sensing layer for the physical world, one that combines LiDAR, radar, vision, RF, and distributed sensing into a continuous and reliable picture of what is happening.
The goal is to see through the occlusions, darkness, distance, and open spaces that camera-only systems miss, while keeping the cost and data footprint low enough to operate continuously at real-world scale.
Three barriers stand in the way of persistent, infrastructure-scale sensing: bandwidth, geometry, and data scarcity.
- First, the sensors that provide the richest view of the physical world also generate enormous amounts of data. A roadside LiDAR can produce point clouds faster than the networks connecting roadside infrastructure can carry them. Compression therefore has to satisfy two requirements at once: preserve small but safety-critical objects such as pedestrians and cyclists, and operate fast enough for real-time use. General-purpose compression methods are poorly suited to this combination. Expanding coverage across multiple LiDARs creates another challenge, requiring independently mounted sensors to be precisely calibrated and synchronized before their observations can be combined.
- Second, some of the most important things to sense are not directly visible. Around-corner radar depends on signals that reach a target only after reflecting off surrounding surfaces. Those surfaces have arbitrary and often unknown geometry, making the sensing problem fundamentally different from conventional line-of-sight perception. More broadly, no single sensing modality works reliably in every condition: vision, LiDAR, radar, and RF each fail in different ways. The challenge is to combine them so that their strengths compensate for one another rather than simply combining their errors.
- Third, the data needed to build these systems is scarce. High-quality, synchronized multimodal datasets are expensive to collect, rare events are inherently underrepresented, and in domains such as marine monitoring, comprehensive ground-truth datasets may barely exist at all.
Our approach addresses each of these barriers directly. For bandwidth, our work on efficient roadside LiDAR compression makes point-cloud data small enough to move without sacrificing the objects that matter for safety. Its network-aware, real-time successor adapts compression to actual link conditions as they change. Roadside multi-LiDAR fusion then combines observations from multiple units to create a wider and more complete view of the environment. For sensing beyond line of sight, Mosaic turns reflector geometry from an obstacle into a resource, using surrounding surfaces to enable omnidirectional around-corner automotive radar. RoVaR addresses multimodal tracking through deliberate diversity across visual and RF sensing, combining modalities at multiple levels so that one can compensate when another becomes unreliable. Finally, we address the data problem by creating new sources of data rather than waiting for them to exist. StreetAware provides a high-resolution, synchronized multimodal dataset of urban environments. G-Litter uses diffusion models and LLMs to augment scarce and imbalanced marine-litter data. Citizen Science for the Sea takes a different approach, collecting marine and litter observations from instruments already carried by recreational boats and effectively turning a distributed community into a large-scale sensor network.
Our AI systems make persistent sensing practical at a scale that individual sensors cannot achieve: moving high-volume sensor data efficiently, extending perception beyond line of sight, combining modalities that fail differently, and creating the data needed to make the resulting systems work reliably.