NEC Laboratories America

Projects | Neural Rendering and Diffusion for Simulation

PROJECTS

Neural Rendering and Diffusion for Simulation

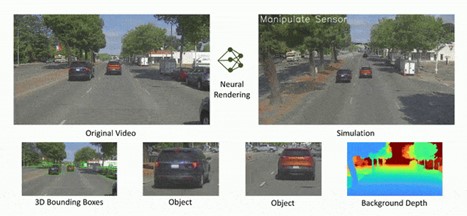
Our simulation framework utilizes advances in neural rendering, diffusion models and large language models to automatically transform drive data into a full 3D sensor simulation testbed with unmatched photorealism. We offer language-based control to generate safety-critical scenarios such as collisions, traffic rule violations and other unsafe behaviors, to improve the perception and planning abilities of autonomous vehicles. While traditional simulation frameworks require expertise from artists, graphics engineers and game engine developers, ours is designed to empower end users with simulation abilities that leverage their domain knowledge.

Our simulation frameworks allow the development of autonomous vehicle AI stacks without the need for exhaustive road testing, while ensuring that training data encompasses diverse real-world conditions.

Team Member: Ziyu Jiang

Publication Tags: NeRF, neural rendering, diffusion model, simulation, autonomous driving
Neural Rendering and Diffusion for Simulation Project
Neural Rendering and Diffusion for Simulation (IRIS-Sim)

Featured Publications

Teaching AI to Edit Driving Scenes It Has Never Seen with HorizonWeaver

Our HorizonWeaver software edits driving scenes with instruction-guided AI, adding traffic, changing weather, and generalizing to unseen roads, all while preserving the safety-critical details that keep autonomous vehicle testing honest.

HorizonWeaver: Generalizable Multi-Level Semantic Editing for Driving Scenes

Ensuring safety in autonomous driving requires scalable generation of realistic, controllable driving scenes beyond what real-world testing provides. Yet existing instruction guided image editors, trained on object-centric or artistic data, struggle with dense, safety-critical driving layouts. We propose

PhyCo: Learning Controllable Physical Priors for Generative Motion

Modern video diffusion models excel at appearance synthesis but still struggle with physical consistency: objects drift, collisions lack realistic rebound, and material responses seldom match their underlying properties. We present PhyCo, a framework that introduces continuous, interpretable, and physically

HorizonForge: Driving Scene Editing with Any Trajectories and Any Vehicles

Controllable driving scene generation is critical for realistic and scalable autonomous driving simulation, yet existing approaches struggle to jointly achieve photorealism and precise control. We introduce HorizonForge, a unified framework that reconstructs scenes as editable Gaussian Splats and Meshes,

LangDriveCTRL: Natural Language Controllable Driving Scene Editing with Multi-modal Agents

LangDriveCTRL is a natural-language-controllable framework for editing real-world driving videos to synthesize diverse traffic scenarios. It represents each video as an explicit 3D scene graph, decomposing the scene into a static background and dynamic object nodes. To enable fine-grained editing and

NEC Labs America Attends CVPR 2026 in Denver, CO June 3-7, 2026

NEC Labs America headed to Denver for CVPR 2026, one of the most prestigious gatherings in computer vision, machine learning, and pattern recognition. The IEEE/CVF Conference on Computer Vision and Pattern Recognition brought innovators from around the world to share breakthroughs.

PhyCo: Learning Controllable Physical Priors for Generative Motion

Modern video diffusion models excel at appearance synthesis but still struggle with physical consistency: objects drift, collisions lack realistic rebound, and material responses seldom match their underlying properties. We present PhyCo, a framework that introduces continuous, interpretable, and physically

Driving the Future of Scene Editing with HorizonForge

HorizonForge introduces a new approach to driving scene generation, enabling precise control over both vehicle behavior and identity. By allowing arbitrary trajectories and flexible vehicle insertion, it creates realistic, scalable simulations for autonomous driving, digital twins, and advanced AI development.

HorizonWeaver: Generalizable Multi-Level Semantic Editing for Driving Scenes

Ensuring safety in autonomous driving requires scalable generation of realistic, controllable driving scenes beyond what real-world testing provides. Yet existing instruction guided image editors, trained on object-centric or artistic data, struggle with dense, safety-critical driving layouts. We propose

HorizonForge: Driving Scene Editing with Any Trajectories and Any Vehicles

Controllable driving scene generation is critical for realistic and scalable autonomous driving simulation, yet existing approaches struggle to jointly achieve photorealism and precise control. We introduce HorizonForge, a unified framework that reconstructs scenes as editable Gaussian Splats and Meshes,

Brownian Bridge Augmented Surrogate Simulation and Injection Planning for Geological CO2 Storage

Geological CO2 storage (GCS) involves injecting captured CO2 into deep sub-surface formations to support climate goals. The effective management of GCS relies on adaptive injection planning to dynamically control injection rates and well pressures to balance both storage safety and efficiency. Prior

Mapillary Vistas Validation for Fine-Grained Traffic Signs: A Benchmark Revealing Vision-Language Model Limitations

Obtaining high-quality fine-grained annotations for traffic signs is critical for accurate and safe decision-making in autonomous driving. Widely used datasets, such as Mapillary, often provide only coarse-grained labels without distinguishing semantically important types such as stop signs or speed

LANGTRAJ: Diffusion Model and Dataset for Language-Conditioned Trajectory Simulation

Evaluating autonomous vehicles with controllability enables scalable testing in counterfactual or structured settings, enhancing both efficiency and safety. We introduce LangTraj, a language-conditioned scene-diffusion model that simulates the joint behavior of all agents in traffic scenarios. By conditioning

AutoScape: Geometry-Consistent Long-Horizon Scene Generation

This paper proposes AutoScape, a long-horizon driving scene generation framework. At its core is a novel RGB-D diffusion model that iteratively generates sparse, geometrically consistent keyframes, serving as reliable anchors for the scenes appearance and geometry. To maintain long-range geometric consistency,

Drive-1-to-3: Enriching Diffusion Priors for Novel View Synthesis of Real Vehicles

The recent advent of large-scale 3D data, e.g. Objaverse, has led to impressive progress in training pose-conditioned diffusion models for novel view synthesis. However, due to the synthetic nature of such 3D data, their performance drops significantly when applied to real-world images. This paper consolidates

Safe-Sim: Safety-Critical Closed-Loop Traffic Simulation with Diffusion-Controllable Adversaries

Evaluating the performance of autonomous vehicle planning algorithms necessitates simulating long-tail safety-critical traffic scenarios. However, traditional methods for generating such scenarios often fall short in terms of controllability and realism; they also neglect the dynamics of agent interactions.

LidaRF: Delving into Lidar for Neural Radiance Field on Street Scenes

Photorealistic simulation plays a crucial role in applications such as autonomous driving, where advances in neural radiance fields (NeRFs) may allow better scalability through the automatic creation of digital 3D assets. However, reconstruction quality suffers on street scenes due to largely collinear

Instantaneous Perception of Moving Objects in 3D

The perception of 3D motion of surrounding traffic participants is crucial for driving safety. While existing works primarily focus on general large motions, we contend that the instantaneous detection and quantification of subtle motions is equally important as they indicate the nuances in driving behavior

AIDE: An Automatic Data Engine for Object Detection in Autonomous Driving

Autonomous vehicle (AV) systems rely on robust perception models as a cornerstone of safety assurance. However, objects encountered on the road exhibit a long-tailed distribution, with rare or unseen categories posing challenges to a deployed perception model. This necessitates an expensive process of

LLM-ASSIST: Enhancing Closed-Loop Planning with Language-Based Reasoning

Although planning is a crucial component of the autonomous driving stack, researchers have yet to develop robust planning algorithms that are capable of safely handling the diverse range of possible driving scenarios. Learning-based planners suffer from overfitting and poor long-tail performance. On

Controllable Safety-Critical Closed-Loop Traffic Simulation via Guided Diffusion

Evaluating the performance of autonomous vehicle planning algorithms necessitates simulating long-tail traffic scenarios. Traditional methods for generating safety-critical scenarios often fall short in realism and controllability. Furthermore, these techniques generally neglect the dynamics of agent

Conditional Image-to-Video Generation with Latent Flow Diffusion Models

Conditional image-to-video (cI2V) generation aims to synthesize a new plausible video starting from an image (e.g., a person’s face) and a condition (e.g., an action class label like smile). The key challenge of the cI2V task lies in the simultaneous generation of realistic spatial appearance and temporal

NeurOCS: Neural NOCS Supervision for Monocular 3D Object Localization

Monocular 3D object localization in driving scenes is a crucial task, but challenging due to its ill-posed nature. Estimating 3D coordinates for each pixel on the object surface holds great potential as it provides dense 2D-3D geometric constraints for the underlying PnP problem. However, high-quality

Divide-and-Conquer for Lane-Aware Diverse Trajectory Prediction

Trajectory prediction is a safety-critical tool for autonomous vehicles to plan and execute actions. Our work addresses two key challenges in trajectory prediction, learning multimodal outputs, and better predictions by imposing constraints using driving knowledge. Recent methods have achieved strong

SMART: Simultaneous Multi-Agent Recurrent Trajectory Prediction

We propose advances that address two key challenges in future trajectory prediction: (i) multimodality in both training data and predictions and (ii) constant time inference regardless of number of agents. Existing trajectory predictions are fundamentally limited by lack of diversity in training data,

A Dataset for High-Level 3D Scene Understanding of Complex Road Scenes in the Top-View

We introduce a novel dataset for high-level 3D scene understanding of complex road scenes. Our annotations extend the existing datasets KITTI [5] and nuScenes [1] with semantically and geometrically meaningful attributes like the number of lanes or the existence of, and distance to, intersections, sidewalks

A Parametric Top-View Representation of Complex Road Scenes

In this paper, we address the problem of inferring the layout of complex road scenes given a single camera as input. To achieve that, we first propose a novel parameterized model of road layouts in a top-view representation, which is not only intuitive for human visualization but also provides an interpretable

Learning To Simulate

Simulation is a useful tool in situations where training data for machine learning models is costly to annotate or even hard to acquire. In this work, we propose a reinforcement learning-based method for automatically adjusting the parameters of any (non-differentiable) simulator, thereby controlling